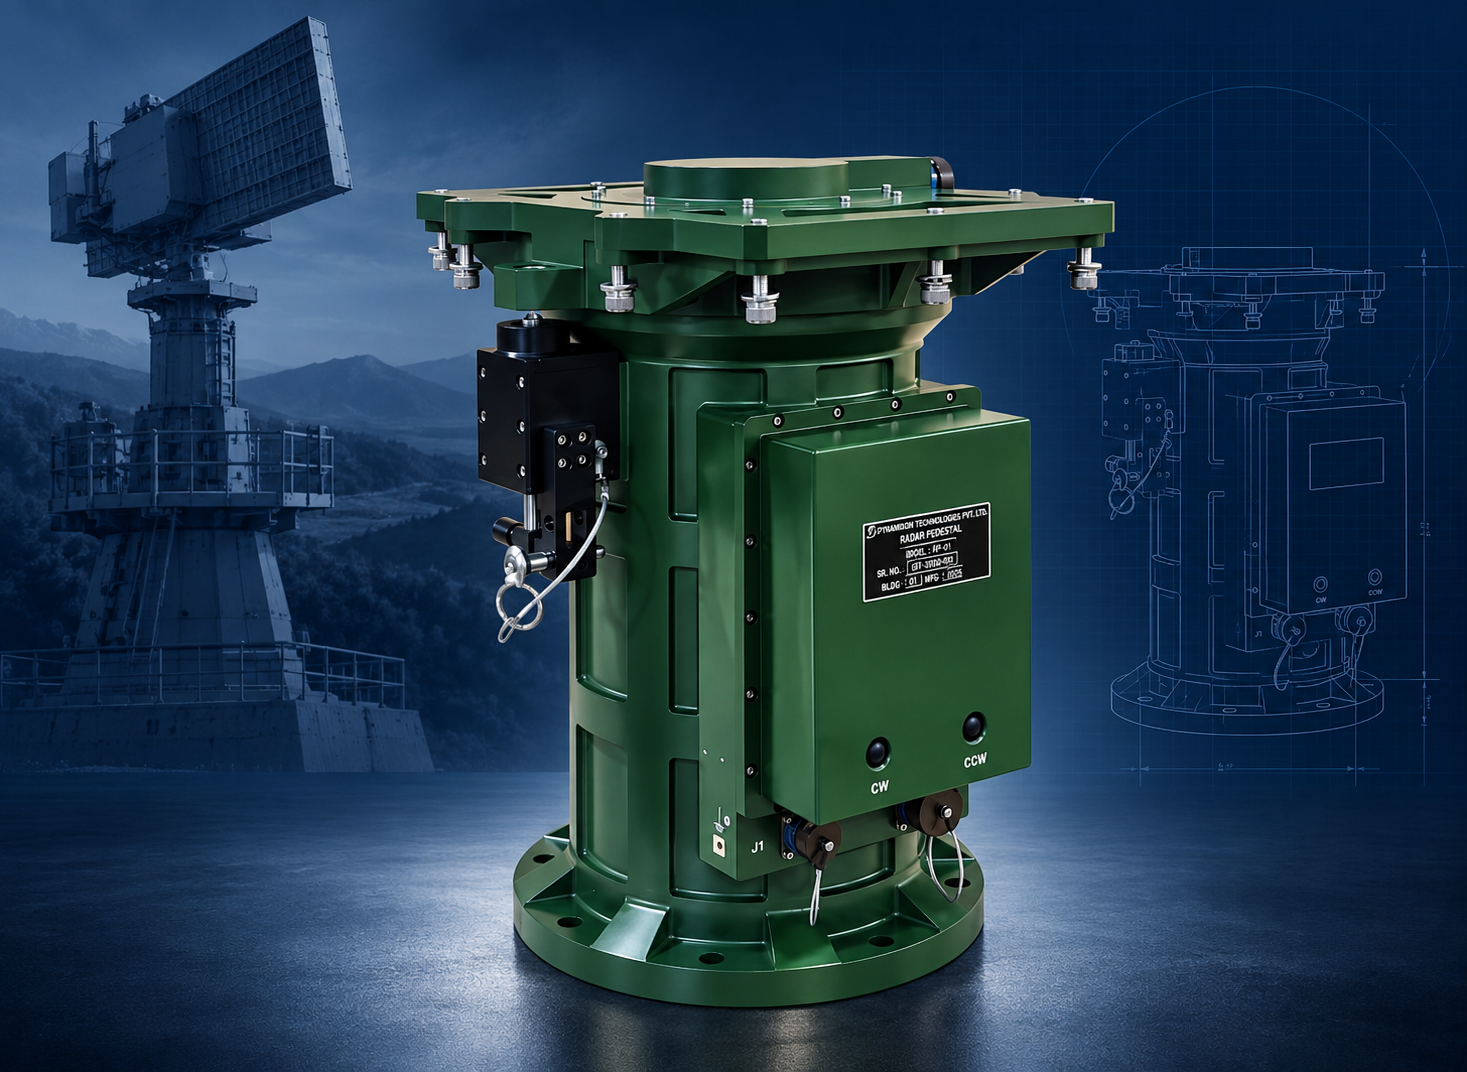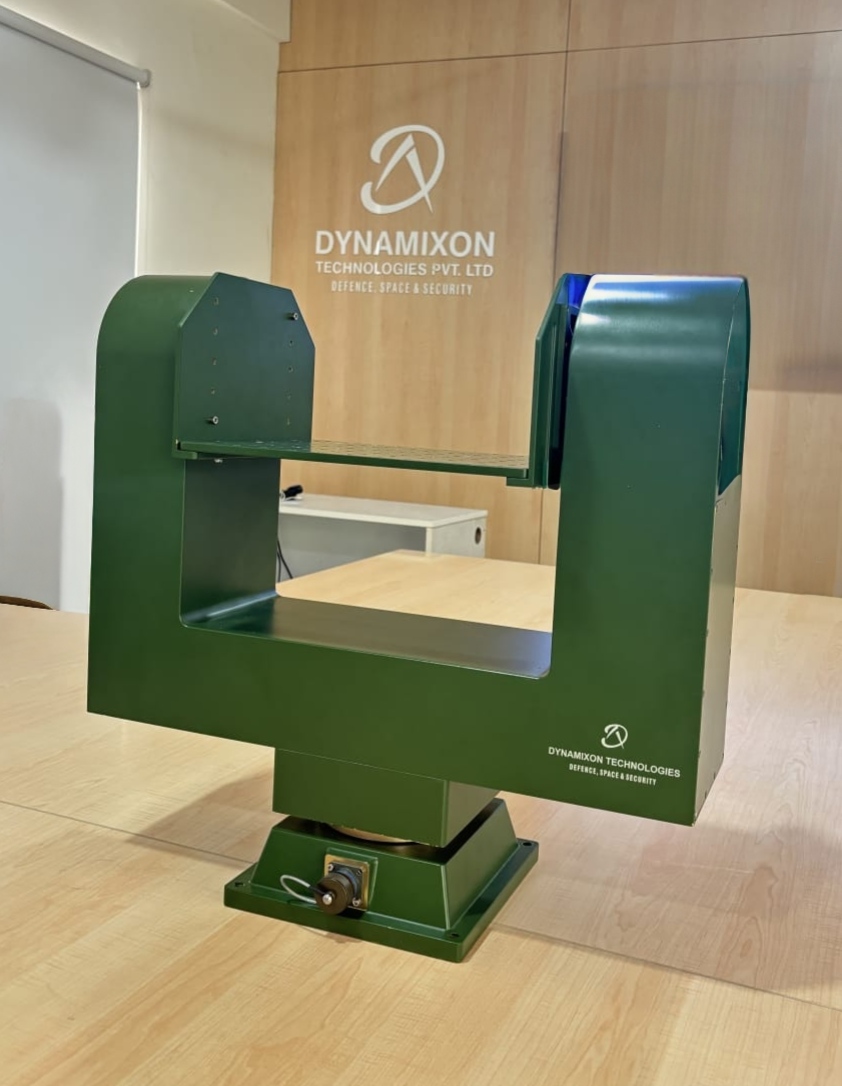
A precision two-axis gimbal system engineered for stabilized positioning of optical and sensor payloads across azimuth and elevation axes.
Designed for platforms requiring stabilized line-of-sight for surveillance, observation and targeting-support applications.
Detailed specifications are available in the datasheet. Please contact us for your requirement.
| Parameter | Specification | Additional Information |
|---|---|---|
| Drive Transmission | Direct Drive Torque Motor | |
| Pan Range | N x 360° | |
| Tilt Range | -15 ° to +80 °/s | |
| Minimum Speed | 0.001 °/s (or better) | |
| Maximum speed | Azimuth: ≥ 80°/s Elevation: ≥ 80°/s | |
| Position Accuracy | ≤ ± 0.01° | |
| Angle Reporting Accuracy | ≤ ± 0.01° | |
| Command update rate | ≥ 100 Hz | |
| Control Execution rate | ≥ 100 Hz | |
| Position Resolution | ≤ 0.001° | |
| Stabilization | ≤ 100 micro radiances in both Az and El direction. Should be capable of stabilizing to ≤ 0.02° RMS br under adisturbance of ± 5° in 3 sec for 40kg payload. | |
| Stabilization enable/disable option | Available/Non available | |
| Scan Sector | Programmable and selectable scan speed and sector | |
| Modes of operation | Position, Rate | |
| Weight | ≤ 80 kg | |
| Input Voltage | 18-32 VDC, Nominal 24VDC | |
| Power Consumption | ≤ 1000 W | |
| Communication | RS-422 | |
| Environmental requirements | Environmental specification based on JSS-55555 Operational temperature: -20°C to 55° C Storage Temperature: -30° to 70°C Damp Heat :99% RH @40°C Salt fog: According to JSS-55555 Vibration: According JSS-55555 Shock: according to JSS-55555 EMC/EMI: According to MIL-STD-461E |